cv
Basics
| Name | Winston Wei-Han Chou |
| Label | Graduate Student |
| winston.ckhs@gmail.com | |
| Url | https://winstonhchou.github.io/ |
| Summary | Aspiring applied scientist and roboticist with a strong foundation in engineering, physics, and management. Currently pursuing a M.S. in Mechanical Engineering (Robotics & Control) at Columbia University. Passionate about advancing robotics, artificial intelligence, and STEM education through research and outreach. |
Education
-
2022.09 - 2026.06 San Diego, United States
Bachelor of Science
University of California, San Diego
BS in Mechanical & Aerospace Engineering, Specialized in Controls & Robotics | GPA: 3.99/4.0
- Robotics: Sensing and Estimation in Robotics (Graduate), Machine Learning for Robotics (Graduate, audited), Robotics (Graduate), Introduction to Autonomous Vehicles
- Control: Linear Control, Signals and Systems
- AI/ML: Machine Learning for Robotics (Graduate, audited), Probability and Statistical Methods for Engineering, Computational Methods in Engineering
- Mechanical: Design of Machine Elements, Computational Methods for Design, Solid Mechanics I, Mechanical Behavior of Materials
Skills
| Software & Embedded | |
| Programming: | |
| Python, C/C++, MATLAB, Java, Javascript, HTML/CSS, LabVIEW | |
| Embedded: | |
| Arm 32-bit Cortex-M7, PlatformIO, OpenOCD | |
| Tools: | |
| ROS, ROS2 (Robot Operating System), Keras, TensorFlow, JAX, PyTorch, Git, Docker, Simulink, Gazebo |
| Mechanical | |
| Tools: | |
| Fusion 360, SolidWorks | |
| Skills: | |
| Machinery, CNC, CAM, FEA, CFD |
| Expertise | |
| System Engineering | |
| Machine Learning | |
| Computer Vision | |
| Motion Planning | |
| Algorithmic Optimization | |
| Sensor Fusion | |
| Control Systems | |
| Embedded Systems |
Experience
-
2025.09 - 2026.08 La Jolla, CA
Undergraduate Researcher, Quadrotor Mapping Team
Advisor: Prof. Nikolay A. Atanasov
- Developed the bidirectional Bubble-Star search algorithm, achieving 5x speedup over A* in 7-D configuration spaces.
- Developed a flow-matching safe bubble planner that learns to imitate expert trajectories while guaranteeing collision-free coverage via bubble-based safety constraints.
- Implemented real-time state estimation with GTSAM’s iSAM2 incremental optimization backend, supporting hardware integration to validate the combined mapping-and-planning stack on UAV hardware.
-
2025.06 - 2025.08 Tainan City, Taiwan
Space Transportation Avionics Intern
Contributed to advancing the TAI-namics Software Stack with a primary focus on progressing from Model-in-Loop (MIL) testing toward Hardware-in-Loop (HIL) implementation.
- Redesigned MATLAB-C++ simulation interfaces, boosting simulation speed by 98% and improving system accuracy.
- Modeled 3D propellant sloshing dynamics using SE(3) screw theory and Lagrangian mechanics, achieving superior accuracy compared to linear models w.r.t. CFD validation.
-
2024.09 - 2025.12 San Diego, CA
Control & Simulation Engineer
Contributed to the development and integration of full-size Indy car racing control and simulation platforms for the Indy Autonomous Challenge (IAC), collaborating with university partners and researchers.
- Developed and integrated control and simulation platforms for a full-size autonomous Indy car in the Indy Autonomous Challenge (IAC), collaborating with university partners to achieve 1st place in the passing tier competition at CES 2025.
- Developed and enhanced Model Predictive Control (MPC) algorithms for a fully autonomous Indy car, introducing grade adaptation into the MPC stack to improve 3D track handling by 75%.
- Validated control algorithm performance by integrating MATLAB Simulink models with dSPACE hardware-in-the-loop (HIL) simulators, closing the gap between simulation and on-track behavior.
-
2024.09 - 2026.06 La Jolla, CA
Teaching Assistant
Support student learning in robotics system integration, computer vision, navigation algorithms, computational strategies, machine learning systems, and vehicle dynamics.
- ECE/MAE 148: Guided 300+ students in autonomous systems through tutorials, office hours, and project mentorship, covering robotics integration, computer vision, machine learning, and system dynamics.
- DSC 190: Guided 30+ data science students in degree-level projects, providing mentorship in data analysis, machine learning, and statistical modeling.
-
2024.06 - 2024.08 Taipei City, Taiwan
Motion Control Intern
Developed features for the Autonomous Mobile Robot (AMR) product line and improved odometry accuracy through sensor integration and control algorithm implementation.
- Developed ROS integrations for real-time AMR position/velocity acquisition and remote PID tuning, and implemented a Ramsete Controller module for odometry-based trajectory tracking.
- Designed encoder accuracy experiments to quantify and correct wheel sensor errors, reducing localization error to below 0.49%.
-
2024.05 - 2026.06 La Jolla, CA
President / Software & Controls Team Lead
Lead software development and autonomous racing for full-scale electric go-kart and F1TENTH teams, participating in international competitions.
- Developed sensor fusion, trajectory optimization, and motion planning algorithms for autonomous racing vehicles, contributing to a 1st place finish in the 2025 Autonomous Karting Series.
- Directed the autonomous racing software stack, integrating real-time feedback and advanced control systems for high-speed navigation.
Volunteer
-
2021.09 - Present Taipei City, Taiwan
FIRST Robotics Mentor
FRC#8020 CyberpunK, C.K. Robotics
Mentor for FIRST Robotics Competition team, guiding students in advanced control theory, robot design, and competition strategy.
- Mentored 300+ high school students in advanced robotics, leading the design, control, and fabrication workflows for multiple award-winning robots across consecutive FIRST Robotics Competition (FRC) seasons.
- Deliver technical instruction spanning model-based control systems, Kalman-filter-based state estimation (sensor fusion with IMU and vision), structural design validation using FEA, mechanical failure prediction via Von Mises and Fatigue theories, factor-of-safety analyses, and hands-on feasibility testing for drivetrain and actuator components.
Awards
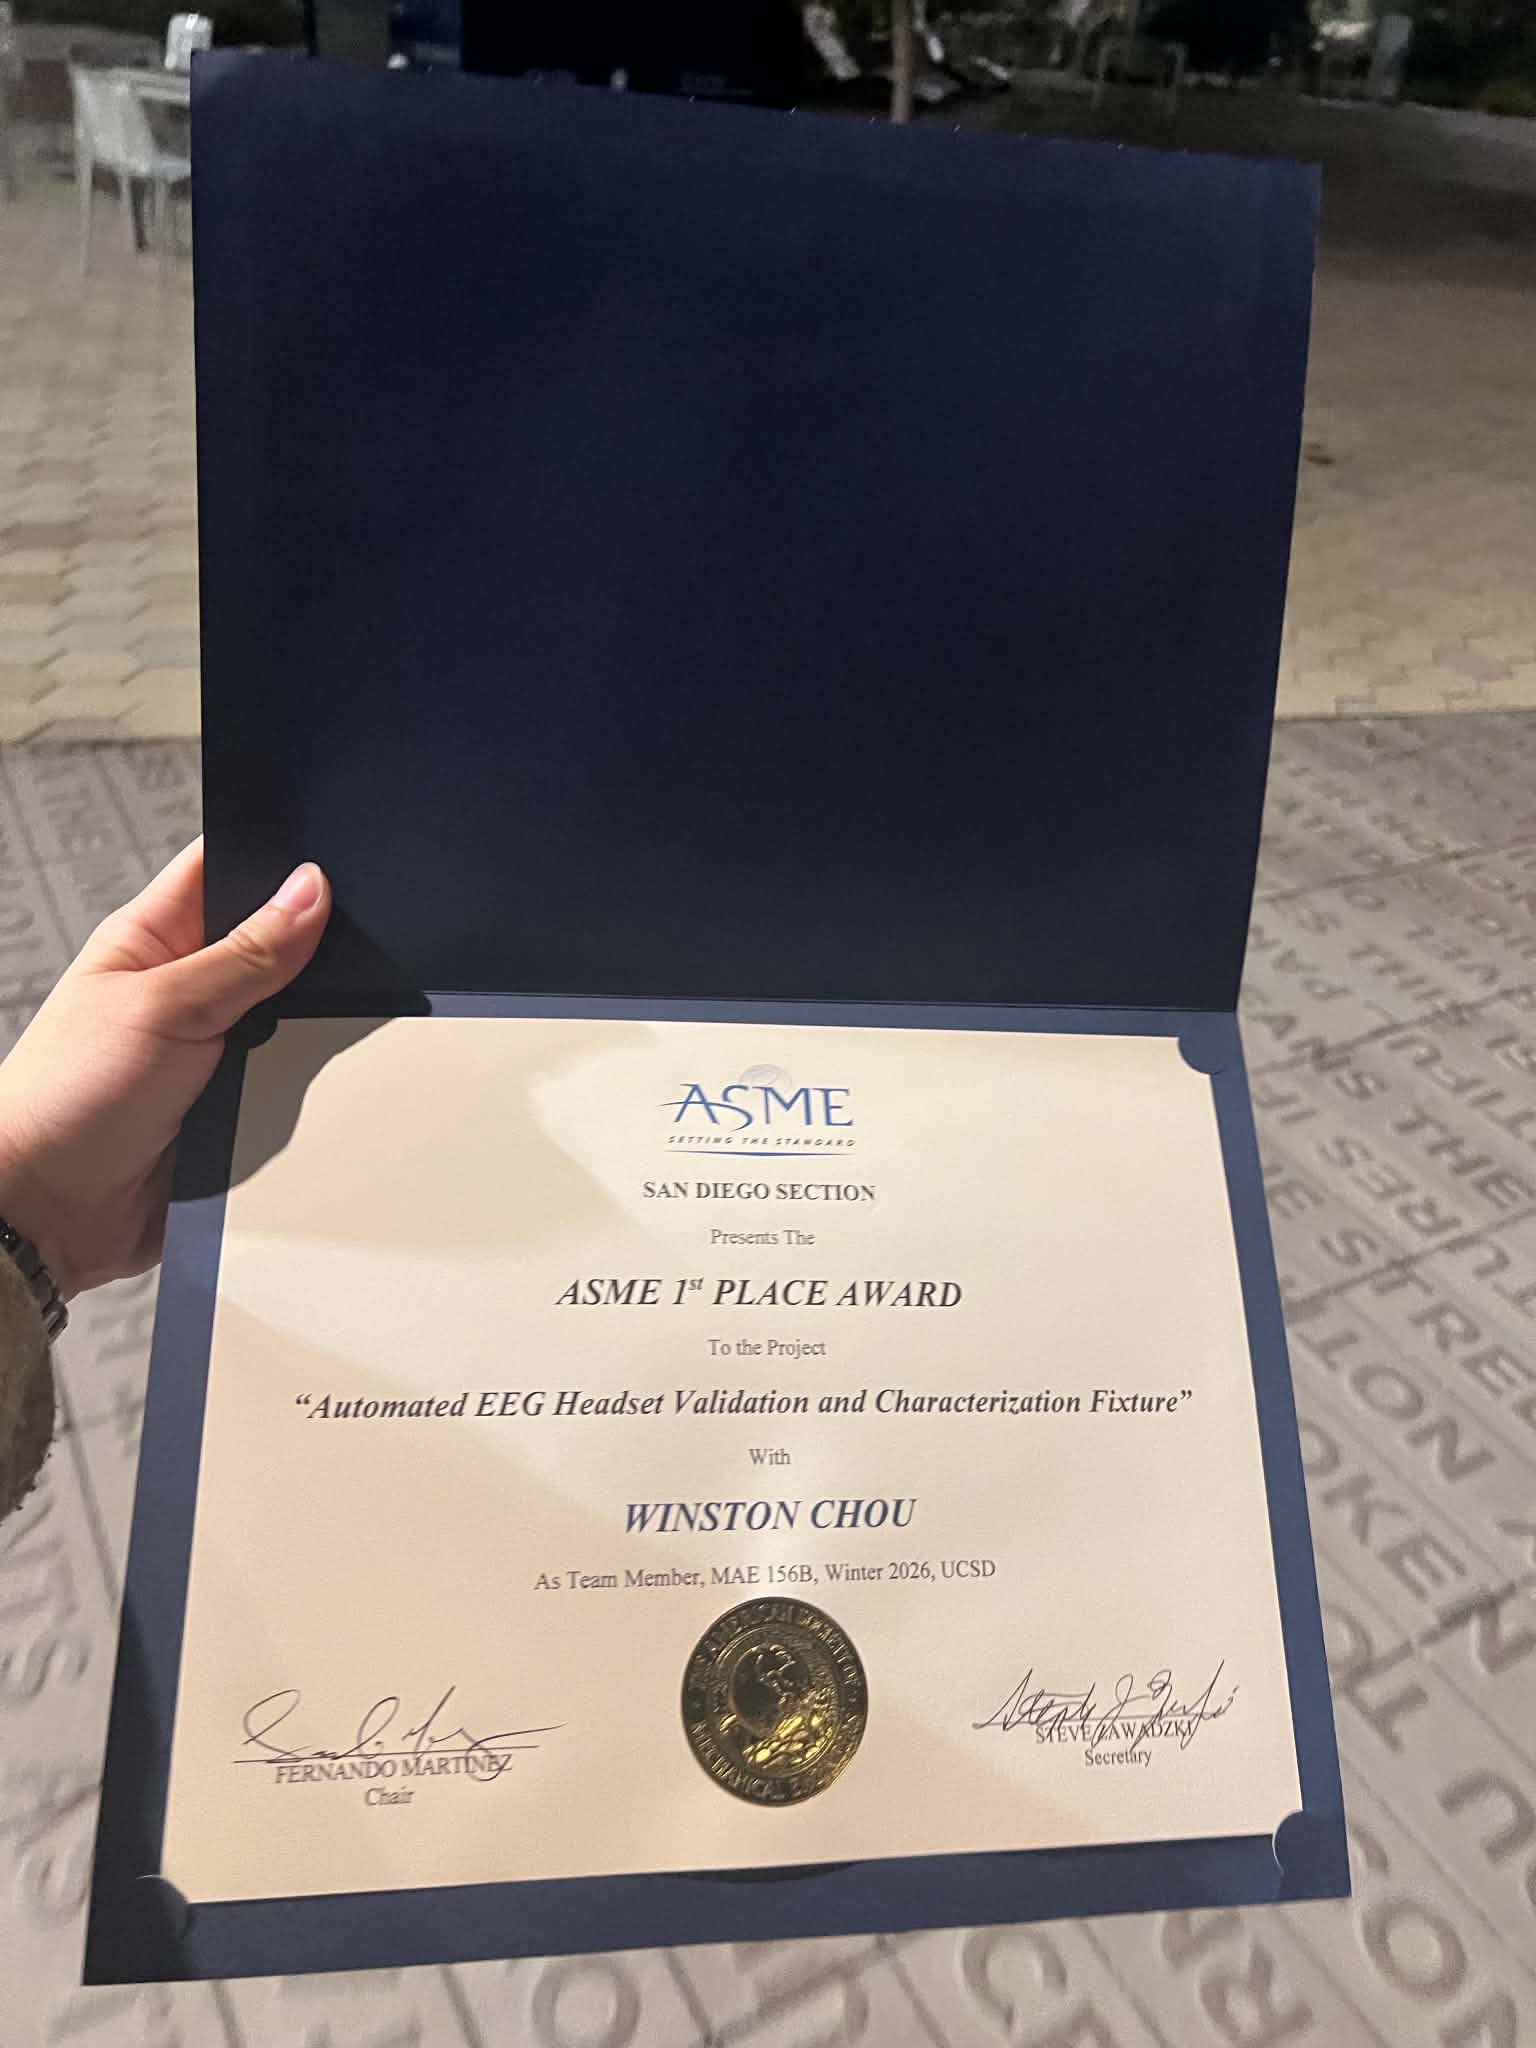
- 2026.04.24
ASME 1st Place Award, San Diego Section
American Society of Mechanical Engineers (ASME)
- 2025.10.25
CKHSAASC Golden Brick Leadership Scholarship Award
Chien Kuo High School Alumni Association of Southern California
Recognize the outstanding achievements of Chien Kuo High School Alumni Association of Southern California (CKHSAASC) student members or the descendants of CKHSAASC members as defined by CKHSAASC Bylaws.
- 2025.03.30
CCBA Southern California Outstanding Youth Achievement Award
Chinese Consolidated Benevolent Association
The Chinese Consolidated Benevolent Association of Southern California's Outstanding Youth Achievement Awards and Model Youth Conference is an annual event hosted by the Chinese Consolidated Benevolent Association (CCBA) of Southern California. It aims to recognize the outstanding achievements of young Chinese Americans and encourage them to actively participate in society and demonstrate leadership. The awards cover a variety of areas, including academic performance, community service, arts and culture, athletics, and innovation, aiming to identify and recognize outstanding young people who have demonstrated outstanding professional and societal contributions.
- 2024.10.26
CKHSAASC Golden Brick Leadership Scholarship Award
Chien Kuo High School Alumni Association of Southern California
Recognize the outstanding achievements of Chien Kuo High School Alumni Association of Southern California (CKHSAASC) student members or the descendants of CKHSAASC members as defined by CKHSAASC Bylaws.
- 2022.06.01
Distinguished Service Award
Taipei Municipal Chien Kuo High School
Serve as Class leader for three consecutive years (10th, 11th, and 12th grades) and actively participate in various school activities, demonstrating leadership and commitment to the school community.
- 2022.06.07
Outstanding Performance Mayor Award
Taipei City Government
Category II Mayor Award (Outstanding Performance Mayor Award): Graduates who have outstanding performance during their studies, such as in sports, skills, arts, science or creativity, club activities, community or school service learning, respect for teachers and parents, acts of helping others, and other specific achievements.